


Boston Dynamics' Atlas robot gets new hands
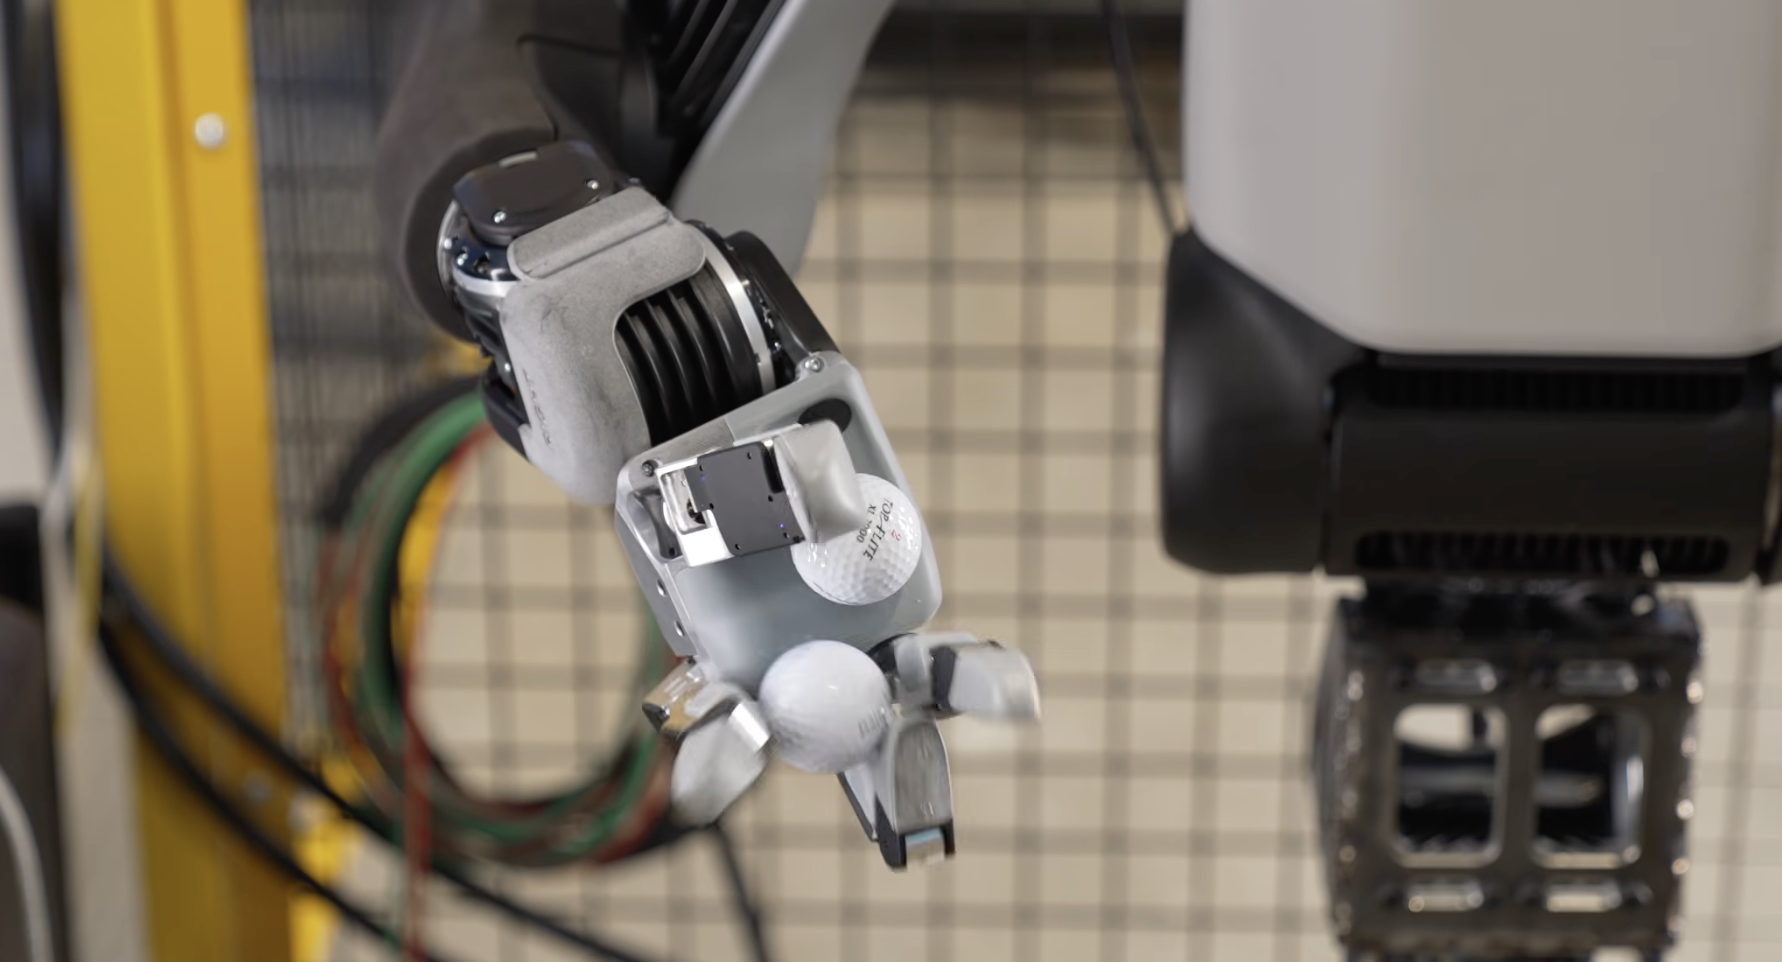
Boston Dynamics has presented a new hand for its high-end robot, Atlas. A new video showcases its new abilities, including handling a drill. Although this demo was conducted with the help of a remote operator, it should demonstrate what will be possible in the near future. Currently, Boston Dynamics is also researching how it can get Atlas to actually learn by itself rather than be trained.
Atlas can already use the new hands fully autonomously. Boston Dynamics demonstrates this with Atlas handling two golf balls in one hand. Atlas can do this without a pinky. According to the company, another finger is not worth the extra complexity it would add. It would also increase power consumption. It's just a thumb and three additional fingers.
The complexity already reaches a level that is close to a separate mini-robot. Atlas' improved hands now offer 13 degrees of freedom, says Boston Dynamics' mechanical engineer Dylan Thrush. Previously, Atlas was limited to 7 degrees of freedom. As the company is planning to use Atlas in car assembly, these additional degrees of freedom will probably come in handy. The new hand is both a bit larger and stronger than a typical human hand.
Boston Dynamics also hopes that the new hand is better at avoiding movements that could damage its mechanical parts because of the extra flexibility.
Source(s)
 Add as a preferred source on Google


No comments for this article
